
English 
+86-157-6313-9515
lina@hezongmaterials.com
lina@hezongmaterials.com
26 Jiashan Road, Chucun Town, Weihai City, Shandong Province, China


Views: 0 Author: Site Editor Publish Time: 2026-07-20 Origin: Site


Frame structural vibration is the primary bottleneck in commercial UAV performance, directly causing Inertial Measurement Unit (IMU) drift, payload stabilization failures, and premature mechanical fatigue. Relying on off-the-shelf structural components severely limits platform capabilities. Generic composite materials often fail to align with the specific natural frequency requirements of custom enterprise, cinematic, or industrial drone platforms. You cannot simply bolt on standard parts and expect optimal flight dynamics when carrying heavy sensors or cinema cameras. Vibration mitigation must start at the structural level. Engineers must optimize the engineered layup, geometry, and resin selection of the carbon fiber tube used for the drone arms before relying on software filters or secondary mechanical dampeners. Building a rigid, resonance-free frame forms the foundation of reliable aerial operations and ensures clean data collection from onboard payloads.
Resonance Tuning is Structural: The primary goal of drone arm design is to push the natural frequency of the frame well above the operating frequency of the motors and propellers.
Layup Dictates Performance: Fiber orientation (e.g., 0°/90° vs. off-axis layers) within a carbon fiber tube drastically alters its stiffness and vibration-damping characteristics.
Geometry Outperforms Mass: Increasing the outer diameter (OD) yields exponential gains in stiffness compared to merely increasing wall thickness, allowing for vibration reduction without severe weight penalties.
Manufacturing Method Matters: Roll-wrapped and filament-wound tubes offer superior multi-directional strength and customization for vibration control compared to standard pultruded alternatives.
The Joinery Factor: Mechanical fastening (drilling) compromises carbon fiber tube integrity and alters vibration paths; structural adhesive bonding is the superior alternative for system damping.
Drones generate a complex spectrum of mechanical noise during flight. High-frequency vibrations originate directly from the propulsion system. Motor imbalances, bearing wear, and magnetic cogging forces create rapid, oscillating stresses that travel straight into the frame. Even microscopic manufacturing defects in motor bells introduce significant kinetic energy into the structure at high RPMs. You will feel this as a high-pitch buzz in the airframe.
Simultaneously, the system battles low-frequency, high-amplitude vibrations. These stem from propeller aerodynamics, blade pass frequencies (BPF), and aerodynamic turbulence. As the propeller blades slice through the air, they create pressure pulses that strike the drone arms. This constant aerodynamic hammering forces the arms to bend and twist continuously. Managing this dual-frequency assault requires a highly engineered structural response.
| Vibration Source | Frequency Range | Primary Cause | Structural Impact on Drone Arms |
|---|---|---|---|
| Motor Imbalance | High (100Hz - 400Hz) | Uneven mass distribution in motor bell | High-frequency micro-oscillations, bearing wear |
| Magnetic Cogging | High (Varies with pole count) | Stator/rotor magnetic interaction | Torsional micro-stresses along the arm axis |
| Blade Pass Frequency | Low to Medium (20Hz - 100Hz) | Propeller wash striking the arm | Vertical bending moments, cyclical fatigue |
| Aerodynamic Flutter | Low (< 20Hz) | Turbulent airflow during forward flight | Lateral bending and yaw-axis twisting |
Engineers model the drone arm as a cantilever beam with a concentrated end-mass. The frame center plate acts as the fixed anchor, while the motor and propeller assembly represents the mass at the free end. This mathematical model allows designers to predict how the arm will behave under dynamic loads in the field.
Applying the Euler-Bernoulli beam theory helps define the natural frequency of the arm. The formula depends on material stiffness, area moment of inertia, mass per unit length, and arm length. By manipulating these variables, designers can shift the natural frequency. The goal is to ensure the arm remains rigid enough to resist bending moments while avoiding the critical frequencies generated by the propulsion system.
When the operational frequency of the motors matches the natural frequency of the frame, resonance occurs. This catastrophic amplification of vibration destroys system performance. In optical payloads, resonance causes the dreaded "jello effect," rendering video footage unusable. For industrial inspection drones, it distorts LiDAR point clouds and introduces severe spatial noise, compromising survey accuracy.
Beyond payload degradation, resonance cripples flight control systems. Structural noise overwhelms gyro sensors, leading to flight controller aliasing. The flight controller misinterprets the vibration as actual movement and issues erratic commands to the Electronic Speed Controllers (ESCs). This constant over-correction increases power draw, overheats motors, and drastically reduces overall flight times.
The ultimate target outcome is achieving an exceptionally high stiffness-to-weight ratio. A stiffer arm possesses a higher natural frequency. You must design the frame so its resonant frequency never overlaps with the propulsion system's operational RPM range. These forcing frequencies must remain well below the structural limits of the arm. Success means the flight controller receives clean sensor data without relying on aggressive, latency-inducing software notch filters.
Carbon composites offer unique advantages over traditional aerospace metals. When analyzing inherent properties, carbon fiber demonstrates a vastly superior stiffness-to-weight ratio compared to 6061-T6 Aluminum and Titanium. However, raw stiffness alone does not solve vibration issues. Engineers must evaluate the Specific Damping Capacity and Loss Factor of the material.
Carbon fiber is exceptionally stiff but requires specific laminate engineering to maximize internal friction. Metals ring like a bell when struck, sustaining vibrations for extended periods. Composites can be tailored to dissipate kinetic energy rapidly. By adjusting the resin matrix and fiber orientation, designers create internal shear forces that convert mechanical vibration into microscopic amounts of heat, effectively damping the structure.
| Material | Density (g/cm³) | Tensile Modulus (GPa) | Specific Damping Capacity | Suitability for Drone Arms |
|---|---|---|---|---|
| 6061-T6 Aluminum | 2.70 | 69 | Low | Poor (Heavy, sustains vibration) |
| Grade 5 Titanium | 4.43 | 114 | Low | Poor (Too heavy for multirotors) |
| Standard Modulus Carbon Fiber | 1.60 | 135 - 150 (Composite) | High (Tunable via resin) | Excellent (High stiffness, low weight) |
| High Modulus Carbon Fiber | 1.65 | 200+ (Composite) | Medium (More brittle) | Good (Maximum stiffness, requires damping layers) |
Pultruded tubes represent the lowest tier of composite structures. Manufacturers pull resin-soaked fibers through a heated die, resulting in purely axial fiber alignment. These tubes completely lack torsional stiffness. They are highly prone to longitudinal splitting and actually amplify vibration under motor torque. Pultruded components have no place in professional UAV design.
Roll-wrapped tubes stand as the industry standard for aerospace-grade drone arms. This process allows engineers to customize the structure layer by layer, achieving an optimal fiber volume fraction. Roll-wrapping delivers superior bending and torsional strength. Filament-wound and braided tubes offer excellent continuous fiber paths for complex torsional profiles. While they possess a slightly lower fiber volume fraction than roll-wrapped options, they provide outstanding structural dampening under heavy dynamic loads.
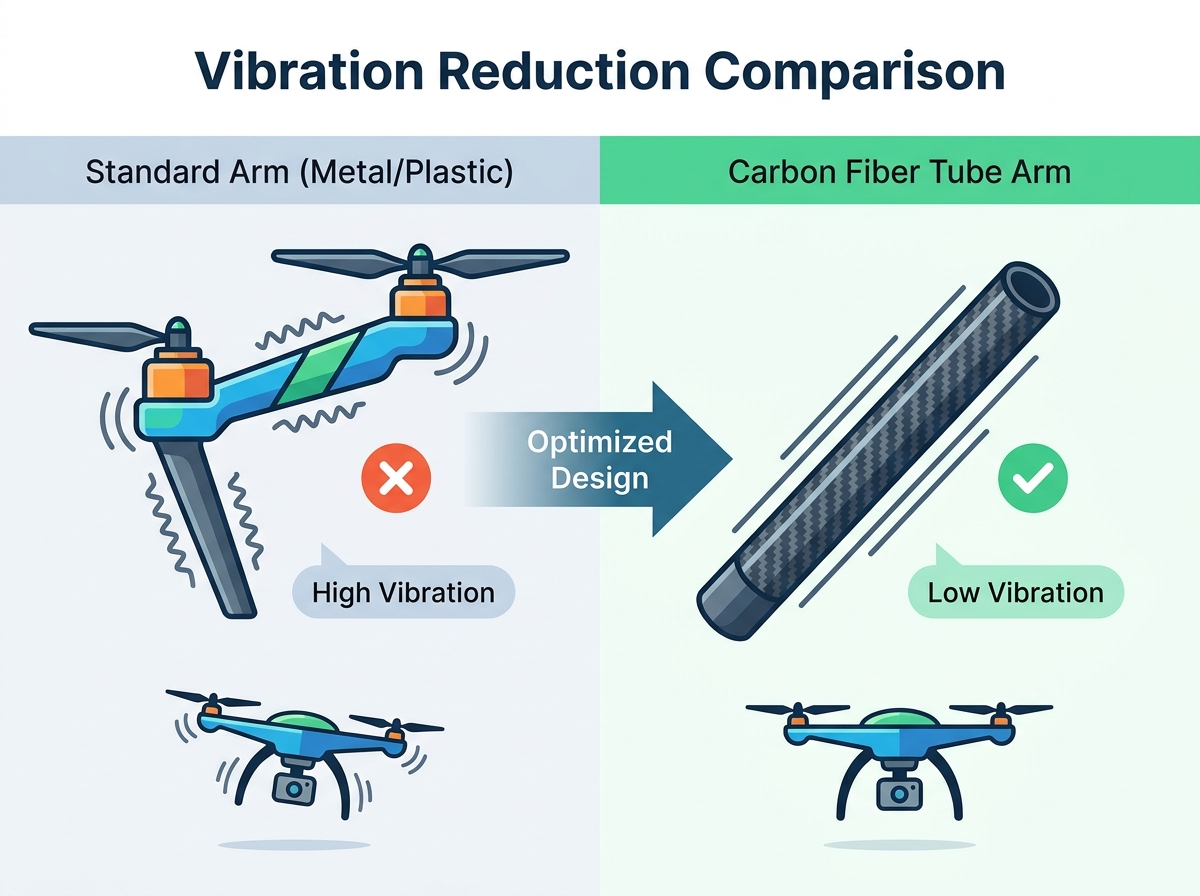
The layup schedule dictates exactly how the tube will handle flight loads. Unidirectional fibers placed at 0° provide longitudinal bending stiffness. These layers resist motor thrust and vertical bending moments, preventing the arm from sagging under heavy payloads. However, a tube made entirely of 0° fibers will fail instantly under twisting forces.
Engineers integrate 45° and -45° off-axis fibers to build torsional rigidity. These layers resist motor torque, yaw-induced twisting, and dynamic shear stresses during aggressive maneuvers. Adding 90° hoop layers provides crush resistance at clamping points and prevents localized buckling. An optimized balanced, symmetric layup template designed specifically for multirotor structural dampening ensures the arm can survive complex, multi-directional flight forces.
Tube geometry plays a massive role in vibration control. The mathematical relationship between tube diameter and the area moment of inertia dictates that stiffness increases exponentially with diameter. Increasing the outer diameter is a far more efficient vibration-damping strategy than simply adding internal wall layers.
Adding wall thickness increases mass linearly, which lowers the natural frequency and degrades flight performance. Expanding the OD provides exponential stiffness gains with negligible weight additions. A large-diameter, thin-walled tube will always outperform a small-diameter, thick-walled tube in both rigidity and resonance avoidance.
The epoxy matrix does more than just hold the fibers together; it actively contributes to viscoelastic damping. As the tube bends and twists, intercellular shear strain occurs between the fiber plies. The resin absorbs this strain, dissipating vibrational energy.
Advanced drone arms often utilize rubber-toughened resins or integrated viscoelastic damping interlayers. Hybridizing carbon with Kevlar or thermoplastic polyurethane plies creates internal shock absorbers. These specialized matrices absorb micro-vibrations before they can travel up the arm and reach the sensitive flight controller.
Engineers must choose between Standard Modulus, Intermediate Modulus, and High Modulus carbon fibers. High-modulus fibers dramatically increase stiffness and raise the natural frequency out of the motor vibration spectrum. This makes them highly attractive for large, heavy-lift platforms.
However, a critical trade-off exists. High-modulus fibers exhibit lower internal material damping. They are also significantly more brittle and costly. While they prevent resonance through sheer stiffness, they transmit high-frequency micro-vibrations more readily than standard modulus fibers. Selecting the right modulus requires balancing ultimate rigidity with the need for internal energy dissipation.
Over-engineering the drone arm leads to severe performance penalties. Adding unnecessary carbon layers increases the moment of inertia of the entire aircraft. This excess mass reduces agility, forces the motors to work harder during directional changes, and drains the battery faster. Engineers must find the exact point where structural stiffness adequately mitigates vibration without compromising the drone's overall payload capacity and flight time.
Round tubes offer uniform multidirectional loading, optimal torsional resistance, and ease of manufacturing. They handle the complex twisting forces of multirotor flight exceptionally well. However, they present a larger aerodynamic profile, increasing drag in forward flight.
Streamlined or oval profiles reduce aerodynamic drag but introduce structural weaknesses. These shapes are highly anisotropic under torsional twisting and prone to lateral vibration modes. For most multirotor applications, the structural superiority of a round tube far outweighs the marginal aerodynamic benefits of an airfoil shape.
Specifying custom roll-wrapped carbon fiber tubes for drone arms requires a higher initial investment compared to adapting commercial-off-the-shelf options. However, the cost-benefit analysis heavily favors custom engineering for enterprise fleets. COTS tubes often lead to sensor failures, reduced lifespan of moving parts, and poor data collection. Investing in custom layups eliminates these downstream operational costs and ensures fleet reliability.
The method used to attach the arms to the frame dictates the survival of the structure. Drilling holes in a composite tube is an engineering hazard. Drilling cuts load-bearing fibers, creates massive stress concentrations, and risks micro-cracking. It introduces a guaranteed failure point under cyclic vibration.
Structural adhesive bonding provides the superior solution. Using aerospace-grade epoxy adhesives to bond tubes into aluminum or carbon sleeves distributes stress evenly across a large surface area. The adhesive layer also acts as an additional joint-damping interface, further isolating the frame from motor vibrations.
Motors and frame center-plates often clamp directly onto the tube. This creates a severe risk of localized compressive stress fractures. Carbon fiber handles tension brilliantly but crushes easily under concentrated clamping loads.
Mitigation requires specific engineering interventions. Designers must specify internal reinforcement sleeves, such as alloy or composite plugs, to support the tube walls from the inside. Alternatively, using precision-machined aluminum split-clamps with exact torque limits prevents the hardware from crushing the laminate and causing delamination.
Long missions generate significant heat. Thermal dissipation from ESCs and motors travels directly into the mounting hardware and the composite arm. This heat affects the Glass Transition Temperature of the tube's epoxy resin matrix.
As the resin heats up, its mechanical properties shift. The damping capacity alters, and the overall stiffness of the arm can decrease. Engineers must select high-temperature resin systems for heavy-lift drones to ensure the structural integrity and vibration characteristics remain consistent from takeoff to landing.
Theoretical modeling must be validated through empirical testing protocols. Engineers perform modal analysis using shaker table sweeps and impact hammer testing to determine the actual resonant frequency and damping ratio of the physical prototype.
Mount the prototype carbon fiber arm securely to a rigid test fixture simulating the drone center plate.
Attach an accelerometer to the free end of the arm where the motor mounts.
Use an impact hammer to strike the arm, exciting its natural frequencies.
Record the frequency response data to identify the primary resonant peaks.
Compare the empirical resonant frequency against the operational RPM range of the intended propulsion system.
Adjust the layup schedule or tube geometry if the resonant frequency falls within the motor's operating band.
Strict procurement criteria guarantee consistent performance across production batches. Manufacturers must adhere to required tolerances for outer and inner diameters, straightness, and fiber volume fraction. Void content must remain below one percent to prevent interlaminar shear failure under heavy dynamic loads.
Effective UAV vibration control must begin with the structural design of the drone arms rather than relying solely on flight-controller filtering or external dampers. The selected carbon fiber tube should combine sufficient bending stiffness, torsional rigidity, and internal damping to keep its natural frequencies away from the motor and propeller operating range.
A balanced roll-wrapped layup using 0°, ±45°, and 90° fibers can resist bending, motor-induced twisting, and clamping pressure. Increasing the outer diameter is generally more weight-efficient than adding excessive wall thickness, while suitable resin systems and reinforced joints help control vibration without compromising durability.
Before production, engineers should validate the tube through modal analysis, vibration testing, and realistic motor-load trials. The best design is not simply the stiffest tube, but the lightest structure that maintains stable resonance behavior, protects sensitive sensors, and withstands repeated flight loads.
A: A mixed, balanced layup is optimal. It must combine 0° fibers for longitudinal bending strength and ±45° fibers for torsional stiffness to resist the complex dynamic forces and yaw-induced twisting of multirotor flight.
A: While thicker walls add mass and alter the natural frequency, increasing the outer diameter (OD) is a far more structurally efficient way to increase stiffness and shift resonant frequency higher without adding unnecessary weight.
A: Pultruded tubes contain almost exclusively unidirectional (0°) fibers, leaving them weak against the twisting forces (torsion) generated by drone motors. Roll-wrapped tubes allow for multi-directional fiber orientation (0°/45°/90°) to handle complex stresses.
A: If the natural frequency of the carbon fiber tube matches the rotational speed (RPM) of the motors, resonance occurs. This amplifies vibrations, leading to sensor aliasing, navigation drift, and unstable flight controller responses.
A: High-modulus carbon fiber increases structural stiffness and shifts the resonant frequency higher—helping the arm avoid motor forcing frequencies. However, it does not inherently possess high internal damping properties to "absorb" vibration; that must be managed via resin choice and hybrid layups.
A: No. Drilling cuts continuous carbon fibers, severely reducing the tube's torsional strength and creating stress concentration zones that can propagate micro-cracks under constant engine vibration. Clamping or adhesive bonding is highly recommended.


